Wednesday, November 28, 2018

Souped-up stepper Motor

Small stepper motors pack a punch despite their limited stature. Such motors are well known for their excellent open-loop positioning characteristics and for delivering relatively high torque, but even higher performance can be achieved with an often overlooked configuration. Fitting a gearhead to a stepping motor can increase torque and resolution, reduce vibration, and let a relatively small motor drive large inertia loads.
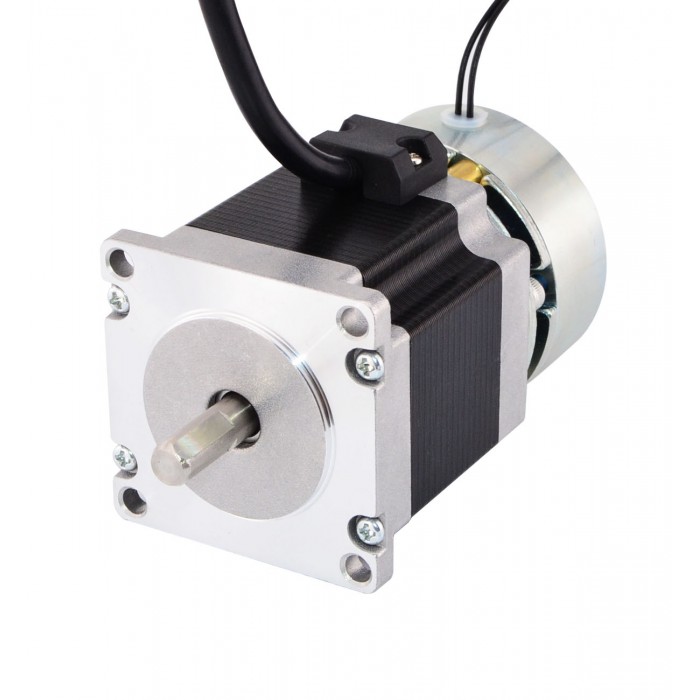
Nema 23 Stepper Motor 1.26Nm(178oz.in) w/ Brake Friction Torque 2.0Nm(283oz.in)

When a gearhead is added to a stepping motor, the increase in output torque can be calculated by multiplying the motor torque at the desired speed times the gear ratio times the efficiency of the gearhead.

Tout = Tmotor x i x η

where
Tout = output torque at gearhead shaft
Tmotor= output torque of stepping motor
I = gear ratio
η = gearhead efficiency


All stepping motors have a resonant frequency in the 150 to 300 steps/sec range, which can cause the motor to vibrate or miss steps. Adding a gearhead can reduce this vibration. In order to obtain the same shaft speed, the frequency of the input pulses needs to be increased. After increasing the input frequency, the motor will no longer operate within the resonant frequency range and will run more smoothly.

Inertia basically determines how quickly a load will accelerate or decelerate. In general, it is recommended that the ratio of load inertia (reflected to the motor shaft) to the rotor inertia be 10:1 or less. The more quickly you intend to accelerate or decelerate, the lower the ratio should be. A gearhead reduces load inertia reflected to the motor shaft by the square of the gear ratio. For example, if a load has inertia of 1,600 oz-in.2 and a 7.2:1 gear ratio is used, the inertia reflected to the motor shaft will be 30.9 oz-in.2


Jref = Jload/i2

where
Jref = reflected inertia at the motor shaft
Jload = load inertia
I = gear ratio

The gearhead ratio also has an effect on step resolution. For example, a 7.2:1 gearhead attached to a stepping motor that moves 0.72°/step would have step resolution of 0.1°/step at the gearhead shaft.

Resout = Motorres/i

where
Resout = resolution at gearhead shaft
Motorres = motor resolution
i = gear ratio of gearhead

No free lunch
Of course, you don’t get something for nothing. There are some tradeoffs when a gearhead is used, such as reduced output speed and positioning errors in the mechanical system. The speed of the gearhead shaft is reduced by the ratio of the gearhead.

Select figure to enlarge.
Ngear = Nmotor/i

where
Ngear = speed at gearhead shaft
Nmotor = motor speed
i = gear ratio

Saturday, November 10, 2018

How do we reduce the resonance level of step motor?

Step motors area unit distinctive among electronic motors in this they move during a series of distinct steps instead of a nonstop motion. this can be a helpful property since it permits steppers to possess point and rate management that's each correct and straightforward and doesn’t even need feedback to keep up . However, one in every of the first disadvantages of this variety of motor comes as a right away results of this distinct nature and open loop management.

How do we reduce the resonance level of step motor?


When a stepper takes one step, it'll overshoot its target destination slightly and can oscillate slightly before subsiding down not off course. this can be due principally to the inertia of the rotating mass in brief overwhelming the field of the motor. This isn’t an enormous deal by itself however once you begin chaining multiple steps along to induce a bigger movement this oscillation happens at every step taken on the manner.

If the frequency that the controller is outputting new step commands to the motor matches the natural frequency of the motor then the oscillations can tend to become additional severe as they propagate through the motor. Eventually they're therefore massive that they're going to overpower the field for long enough on a given step to miss the following step command, and you start missing steps. Since steppers area unit usually run in open loop, the controller has no data of those lost steps; The result's the motor won't get to its destination with success. The impact will become therefore pronounced that the motor loses force utterly and stops rotating. betting on the synchronization of the steps, it will even reverse the direction of rotation.

Wednesday, November 7, 2018

Open-loop Position Control with a Stepper Motor

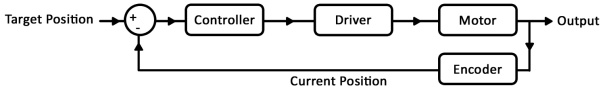
First, let's take a look at what the control system looks like on a stepper motor without an encoder. Suppose you want the stepper to make one complete rotation. Your program knows your motor’s step angle is (for example) 1.8°, so it tells your controller to move 200 steps clockwise. The controller tells this to the driver chip, and the driver chip outputs the power signals that turn the motor. Next, suppose you want the motor to turn half a rotation counter-clockwise from it’s original starting location. Your program remembers the motor is 200 steps away from the starting position, so it tells the controller to move 300 steps counter-clockwise, and so on.

openloop

This is known as open-loop control not closed loop control. You have precise control over the position of the motor, but only under the assumption that the motor has physically done exactly what it’s been told to do. If the motor takes an extra step due to excessive inertia, if the motor stalls, or if you’re using a stepper motor with gearbox that has significant backlash, your program’s assumption of the motor’s current state will be wrong.


Closed-loop Position Control with a DC Motor and Encoder
Now we’ll look at the control system that results from using a DC motor and encoder. Suppose you want the motor to make one complete rotation. Your program tells the controller to move at 100% duty cycle. The motor starts moving, and as it does, the encoder updates your program with the motor’s current position. The program then re-evaluates the situation and tells the controller a new duty cycle.

closedloop

Friday, November 2, 2018

Four types of waveforms and sequences drive for stepper motors

There are four types of waveforms, or sequences, through which stepper motors are driven. These are:

1. Wave drive;

2. Full step drive;

3. Half step drive;

4. Micro stepping – we will present this method and when it is employed in another article.

Wave drive
By using this method, a single phase of a cheap stepper motor is energized at a time. If we refer to figure 1 below we can see how a stepper motor is driven. We can observe that there are 3 phases (f=3), AA’, BB’ and CC’ and 2 teeth (z=2) North and South. The rotor will perform full steps, with the angle: Theta=360/(f*z)=60 degrees.


Full step drive
When the rotor of the motor depicted in figure 1 reaches position 3 we can see that the motor can also be driven by having two phases energized at the same time. The rotor will perform full steps, according to the formula above, aligning itself exactly in the middle of the angle between the stator poles, North and South. This drive method provides full torque of the motor.

The sequence will be:

AA’BB’CC’
110
011
101
110

Half step drive
This method implies alternately powering either one phase or two phases at a time. The rotor will align itself either with stator poles, as in wave drive, or between them, as in full step drive. In this case the rotor will have 30 degree step angles.

The sequence is:


The direction of rotation in either case is determined on how the sequence is started. Sequences presented above assume clockwise rotation when applied starting from the first row and counter-clockwise rotation when started from back to front.


So, if we look at figure 1, depicting a 2-phase bipolar stepper motor like the one we want to control, we can determine the control sequences for each method mentioned above. It can be observed that such a motor has 4 leads, corresponding to 4 pins of an output controller or interface. So the sequences will be:

• Wave drive: 1000 0100 0010 0001;

• Full step drive: 1100 0110 0011 1001;

• Half step drive: 1000 1100 0100 0110 0010 0011 0001 1001.

See more:


Saturday, October 27, 2018

How to Choose A Suitable Rotation Speed Stepper Motor

While we chose a stepper motor online supplier , according to the speed, it is very to choose a motor working at the best situation. The stepper motor speed divided into :working at low speed, working at a more than 2000rpm speed and working at a wide range from low speed to high speed. The choice of stepper motor will be different.

While operated at a high speed, because of the influence of circuit inductance, the flow of the circuit current will be limited. Assuming that the coil reactance of the 1 phase is X, the frequency angular velocity of the driver current is w(electric angle), Its synchronous rotating rotor mechanical angle is wm, at high speed, the coil resistance R<<X, the impedance Z of the 1-phase winding becomes the following:

Z≈wL=NRwmL  (5)
How to Choose A Suitable Rotation Speed Stepper Motor


When the rotor rotates at the rotation speed wm, the impedance Z requires that the number of teeth N of the rotor is as small as possible so that the current easily flows. In addition, the stator is driven by a constant current. If the rotational speed is too high, the cross-flow control cannot be achieved, and it will become a constant-voltage drive. When the rotation speed is high, this state is often driven. In this state, when the applied voltage is V, if The electromotive force is E, then its current I is determined by the following formula:

İ=(V(.)-E(.))/Z      (6)

Z=NrwmL

Figure 5.1 Equivalent circuit when rotating at high speed

The current I of the motor with small Nr rotation speed is large. The step angle is determined by the formula θs=π/PNr. If the number of gears Nr is small, the step angle of the stepping motor is large. When operating at high speed, select a stepper motor with a large step angle. On the contrary, it is more appropriate to drive a motor with a small step angle at a low speed.

Low-speed operation tends to produce vibration or resonance. In order to avoid or reduce vibration, the step angle of the motor is small, and the two-phase motor is not as good as the three-phase motor. Further analysis, full stepper motor is not as good as half stepping and stepping. In addition, a motor with a large number of rotor gears has a large torque at a low speed. When using at low speed, use direct drive as much as possible without using a reducer. This is because a stepper motor with a small step angle has a high speed-to-torque characteristic and a large drop in slope at low speed, which is suitable for low-speed operation.

Related Links:
https://oyostepper.weebly.com/blog/how-to-run-2-step-motor-wh-2-rotary-encoders
http://www.createdebate.com/debate/show/Which_is_Better_Nema_23_vs_Nema_17_for_the_engineering_challenged

Tuesday, October 23, 2018

Which is better? Servo motor or stepper motor?

The overwhelming majority of linear motion applications (with the exception of pneumatically-driven types) use either a stepper motor or a servo motor to provide torque to the driving mechanism, which is typically a ball or lead screw, rack and pinion, or belt and pulley system. And unlike other components involved in linear motion, when choosing a motor, there is usually a clear answer to the question, “Which technology should I use?” This is because servo motors and stepper motors are designed for very different performance characteristics. Determining which is to use for a given application requires understanding these differences and balancing them with other factors, such as cost and complexity.


Positioning
The basic premise of a servo motor is that it operates in a closed loop motor system, meaning that an encoder or feedback device sends signals to the controller indicating the actual position of the motor. This information is compared against the commanded position, and the controller sends corrective signals to the motor in order to minimize the error. The result is very tight positioning accuracy and more reliable positioning than can be achieved with stepper motors. However, closed loop systems require tuning of the control parameters and are more time-consuming to set up. The additional components required for feedback and greater complexity also make them more expensive than steppers.

Speed
A general rule is that stepper motors are best suited for applications that run at 1000 rpm and below. This is because at higher speeds, a stepper motor’s torque production drops off rapidly. Servo motors can operate at a wide range of speeds, and they’re usually the better choice for high-speed applications.

Torque
As mentioned earlier, a stepper motor rapidly loses torque capability as its speed increases, with torque typically falling off at speeds above 1000 rpm. However, at lower speeds, steppers have excellent torque-producing capability for a given motor size. It’s important, however, to never exceed a stepper motor’s rated torque (which can limit its ability to accelerate), because doing so can result in lost steps or cause the motor to stall.

Which is better? Servo motor or stepper motor?

The verdict
In general, servo motors are the better choice for applications that require precise and accurate positioning, high speeds, and/or the ability to withstand changing loads (especially those that might require higher than the rated motor torque). For applications that don’t require position feedback and that operate solely within the design limits of the motor, stepper motors from china provide a simpler, more cost-effective solution.

How to Run 2 step motor w/h 2 rotary encoders

How to Control a Step Motor with a Rotary Encoder


Friday, October 12, 2018

NEMA 11 Stepper Motor dual shaft 0.67 Amps Description

This is the smallest stepper motor we've featured to date, but it still packs a nice punch in a compact, rectangular NEMA 11 form.

NEMA 11 Stepper Motor dual shaft 0.67 Amps


Description:
This micro stepper motor is small enough to fit in the palm of your hand but still features 16.7 oz-in of holding torque. These NEMA 11 or nema 14 stepping motors are perfect for small CNC machines, 3D printers, laboratory assistance, linear actuators, telescopes, pick and place machines, and prototyping machines. Single shaft .187 inch (4.75mm)

Technical Specifications:
1.8 degree stepping angle (200 steps/revolution)
Rated Voltage: 6.2V
Current/Phase: .67 A
Resistance/Phase: 9.2 ohms
Inductance/Phase: 5.7mH±20%(1KHz)
Holding Torque: 16.7 oz-in / 1200 g-cm
Number of Leads: 4
Rotor Inertia: 18 g-cm2
Weight: 0.44 lbs / 0.2 kg
Length: 50.5 mm


Innovation methods of a hollow rotary actuator

1.What is a hollow rotary actuator? A hollow rotary actuator is an integrated electromechanical assembly that produces controlled rotationa...